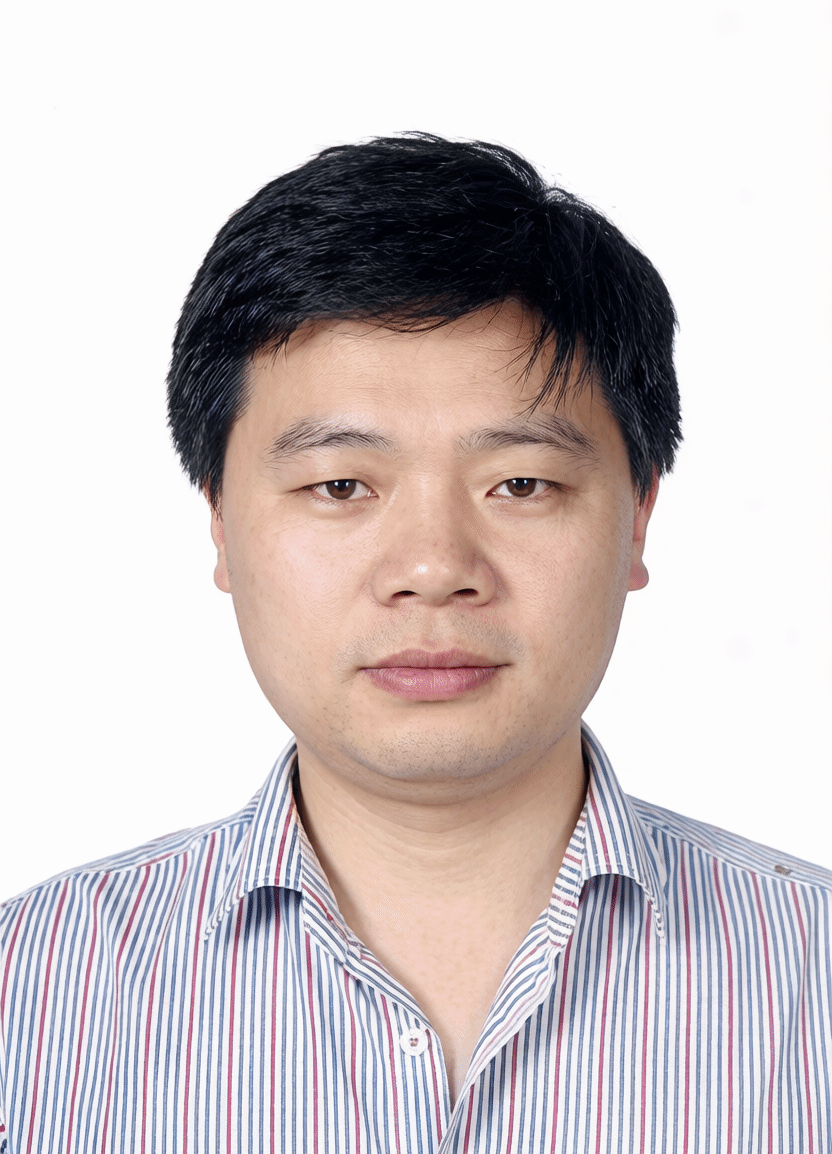
姓名:祝贵兵
职称:副教授
导师身份:浙江海洋大学硕士生导师、博士生导师
学科方向:船舶与海洋工程(轮机工程)、交通运输(交通信息工程及控制)
Email:zhuguibing2020@zjou.edu.cn
学习工作简历:
学习简历:
201509 - 201912 大连海事大学,控制理论与控制工程专业,工学博士学位;
200206 - 200807 大连海事大学,交通运输工程专业,工学硕士
200209 - 200607 大连海事大学,航海技术,工学学士。
工作简历:
200909 - 201508 浙江海洋学院, 港航与交通运输工程,讲师
202001—202112 浙江海洋大学, 船舶与海运学院,讲师
202201—至 今 浙江海洋大学, 船舶与海运学院,副教授
研究方向
[1]船舶自主航行控制技术
自主航行制导与控制、自主航线规划、自主航行避障、多船协调控制
[2]无人船舶网络化控制
智能船舶远程操控、网络控制与攻击预防、无人船艇-无人机网络化协同巡航
[3]海上环境感知
基于视觉的多类型海上物标识别、海上小目标监测与识别、复杂航行场景增强。
科研项目
[1]浙江省自然科学基金委,面上项目:欠驱动智能运输船舶自动靠泊控制方法研究,2020/01-2022/12,10万,主持;10万 (结题)
[2]浙江省舟山市科技局,一般项目:网络环境下的智能运输船舶自动靠泊控制方法研究,2022/01-2024/12,主持,10万(结题)
[3]国家自然科学基金委,国际间合作:粤港澳大湾区智慧海事保障平台立体协同作业关键技术研究,2023/01-2026/12,课题负责人,50万(在研)
[4] 浙江省应急管理厅,科技攻关项目:浙江沿海强台风在港渔船综合应急抗台与安全保障关键技术研究,2024/01-2024/12,主持,98.5万(结题)
[5] 国家自然科学基金委,面上项目:多重约束下智能运输船舶安全航行自适应控制方法研究,2026/01-2029/12,主持,50万 (在研)
[6] 国家自然科学基金委,区域创新联合重点:江淮干线岸基驾控船舶智能航行决策及控制方法研究,2026/01-2029/12,课题负责人,50万 (在研)
代表性论文著作
[1]G. Zhu, J. Li, Y. Ma, Z. Li and M. Sotelo. 3-bit Transmission Mechanism-Based Adaptive Neural Path Following Control of 4DOF Underactuated USVs via Error-Constraint ILOS Approach[J]. IEEE Transactions on Intelligent Transportation Systems, doi: 10.1109/TITS.2026.3708115, 2026.
[2]G. Zhu, X. Peng, Y. Ma, and S. Hu. FTILOS-based path following control for underactuated USVs with obstacle avoidance: a planning-guidance-control integrated design[J]. IEEE Transactions on Industrial Electronics, vol. 73, no. 6, pp. 8872-8883, June 2026.
[3]Zhu G. , Liu Y. and Qiu J. Dynamic event-triggered adaptive neural practical predefined-time control for uncertain nonlinear systems with unknown control directions[J]. IEEE Transactions on Systems, Man, and Cybernetics: Systems, 2025, 55(11): 7629-7638.
[4]Zhu G., Li J., Ma Y., and Hu S. FT-ILOS-based adaptive fuzzy path following of USVs under input saturation via parallel-self-triggered approach[J]. IEEE Journal of Oceanic Engineering, 2025, Doi: 10.1109/JOE.2025.3551038
[5]Zhu G., Wu C., Ma Y., and Hu S. Resource-constrained adaptive neural output feedback security control for networked USVs under dual-channel malicious attacks[J]. IEEE Transactions on Vehicular Technology, 2025, 74(7): 10109-10121.
[6]Zhu G., Xu Z., Gao Y, et al. Periodic event-triggered adaptive neural output feedback tracking control of unmanned surface vehicles under replay attacks[J]. Engineering Applications of Artificial Intelligence, 2025, 146: 110237. (SCI, JCR一区)
[7]G. Zhu, Y. Ma and S. Hu. Event-sampled adaptive fuzzy control of MASS via intermittent position data[J]. IEEE Transactions on Emerging Topics in Computational Intelligence, 2025, 9(4) : 3084 - 3096. (SCI, JCR一区)
[8]祝贵兵,吴晨,马勇. 虚假数据注入式攻击下无人水面船舶自适应神经输出反馈轨迹跟踪控制[J]. 自动化学报,2024, 50(7): 1472−1484.
[9]Zhu G., Ma Y, Hu S. Event-triggered adaptive PID fault-tolerant control of underactuated ASVs under saturation constraint [J]. IEEE Transactions on Systems, Man, and Cybernetics: Systems, 2023, 53(8), 4922-4933. (SCI, JCR一区)
[10]Guibing Zhu, Yong Ma, Zhixiong Li, et al. Dynamic event-triggered adaptive neural output feedback control for MSVs using composite learning[J]. IEEE Transactions on Intelligent Transportation Systems, 2023, 23(7), 7045-7057. (SCI, JCR一区)
专利及获奖:
[1]中国航海学会科技进步二等奖:复杂水域船舶智慧航行平台关键技术研究及应用,2022,6/11;
[2]中国产学研合作创新一等奖:面向航海实践融合机器学习的船舶智能运动控制技术研发及应用,2022,4/10;
[3]湖北省技术发明二等奖:复杂场景下船舶自主航行及协同控制关键技术与应用,2023年,3/6;
[4]中国海洋工程咨询协会海洋工程科学技术二等奖:多重约束下融合智能计算的船舶自主协同控制理论与技术,2023年,2/9;
[5]中国发明协会发明创业奖成果一等奖:AI 赋能船舶自主航行可信控制关键技术及应用,2025年,3/6;
[6] 祝贵兵,马勇,卢金树,喻淑兰,陈超. 一种基于复合学习的水面船舶动态事件触发控制方法,ZL 2022 1 1125909.0;
[7] 祝贵兵,彭鑫鑫,潘宝峰,卢金树,马勇. 一种无人水面船舶避障导航路径生成与跟踪方法和装置,ZL 2025 1 1523517.3;
[8] 潘宝峰,祝贵兵,史慧敏,朱凡,支宏扬. 一种基于ViT的海上小目标检测方法, ZL 2024 1 0520403.2;
[9] 祝贵兵. 海洋水面船舶先进控制理论与方法[M].水利水电出版社,2024.


 当前位置:

